Skip to content
CELOS

Control, Estimation, and Learning for Optimal Systems

Hanyang University

School of
Electrical Engineering

Learning-based optimal control for autonomous systems

About CELOS

● The CELOS Lab. conducts research on learning-based optimal control and estimation, covering the control of autonomous vehicles/robots, and the sensor fusion system used in autonomous systems, such as Radar/LiDAR/Camera/IMU.

● CELOS 연구실은 학습 기반 최적 제어 및 추정을 연구합니다. 자율주행차량과 자율로봇의 제어 뿐만 아니라, 자율시스템에 들어가는 Radar, LiDAR, Camera, IMU 등의 다양한 센서를 융합한 시스템을 설계합니다.

[Keywords]

  • Sampling-based model predictive control
  • Reinforcement learning
  • Diffusion policy
  • Autonomous driving/robot
  • Sensor fusion
  • AI edge controller
Seungho Han

Principal Investigator

Seungho Han 한승호

Assistant Professor, Electrical Engineering and Mechanical Engineering (joint appointment), Hanyang University

Welcome to the CELOS Laboratory!

Office
Room 402, Engineering Building 3 (제3공학관 402호)

Research Goals

1. Sampling-based optimal control for autonomous driving/robots

● Our lab conducts research on optimal control-based autonomous mobility. We utilize optimal control to achieve multiple objectives under uncertainty.

▸ Kor.

우리 연구실은 최적제어 기반 자율 모빌리티를 연구합니다. 최적제어를 통해 불확실함 속에서 여러 목표를 달성합니다.

  1. 1. Stochastic MPC for outdoor autonomous driving & collision avoidance

  2. 2. Indoor autonomous driving using sampling-based MPC

  3. 3. Precise collision avoidance using superquadric potential function

2. Reinforcement learning and digital twin for autonomous systems in complex environments

● Our lab conducts research on reinforcement learning-based optimal control. We transfer real-world robots and mobile platforms into simulated environments to enable autonomous operation even in complex terrains and obstacle-rich scenarios.

▸ Kor.

우리 연구실은 강화학습과 디지털트윈을 연구합니다. 현실세계의 로봇과 모바일을 시뮬레이션 world에 옮기고, 복잡한 지형이나 장애물이 많은 상황에서도 자율적으로 움직일 수 있도록 반복적으로 강화학습을 적용합니다.

  1. 1. Wheeled-legged robot control using RL (Winner, WLR workshop competition, IROS 2025)

  2. 2. Spider robot control in rough terrain (Diden Robotics)

  3. 3. Mobile manipulator control

3. State estimation using various sensors under uncertainty

● Our lab develops methods to estimate the motion of vehicles and robots under uncertainty. We utilize sensors such as LiDAR, radar, cameras, GPS, and IMU, and incorporate various techniques to handle the measurement uncertainties inherent in these sensors.

▸ Kor.

우리 연구실은 불확실성 속에서 차량과 로봇의 움직임을 추정하기 위한 방법을 연구합니다. 이를 위해 라이다, 레이다, 카메라, GPS, IMU 센서를 활용하며, 센서에 존재하는 측정 불확실성을 다루기 위해 다양한 기법을 도입합니다.

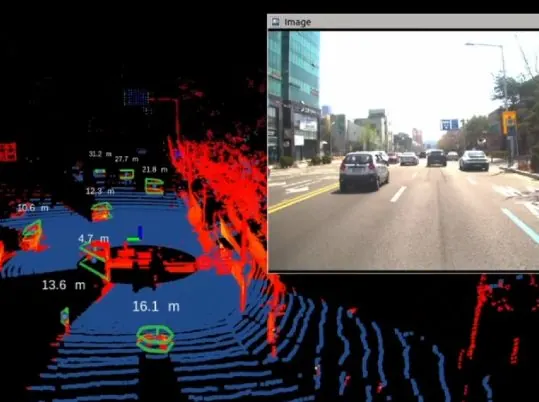
  1. 1. Multi-object tracking using 4D radar and LiDAR

  2. 2. Bias-removed EKF for robust pose estimation

etc.

Previous projects

  • Robust Indoor Autonomous Mobile Manipulator

    Robust Indoor Autonomous Mobile Manipulator

    2024-2025, KAIST MSC Lab.

  • Military Autonomous Tractor-Trailer System

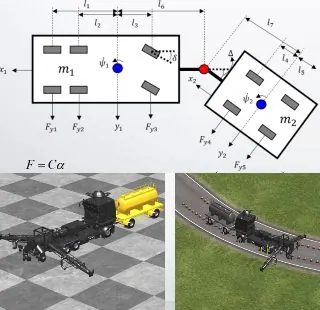
    Military Autonomous Tractor-Trailer System

    2019-2022, KAIST, Republic of Korea Air Force, KIMM, Treeze Engineering

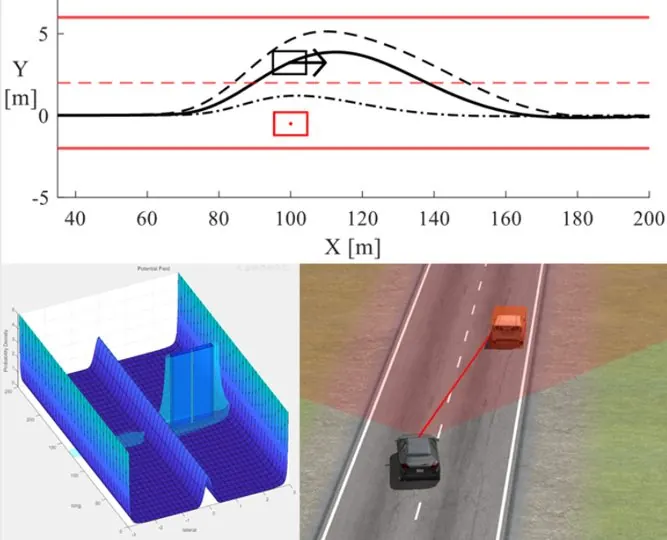
  • Collision Avoidance of Autonomous Vehicle Using Robust Potential Function and Nonlinear MPC

    Collision Avoidance of Autonomous Vehicle Using Robust Potential Function and Nonlinear MPC

    2022-2023, KAIST

  • 3D/4D Radar-based ADAS and Autonomous Driving Systems Integration

    3D/4D Radar-based ADAS and Autonomous Driving Systems Integration

    2022-2024, KAIST, FEV, Daedong

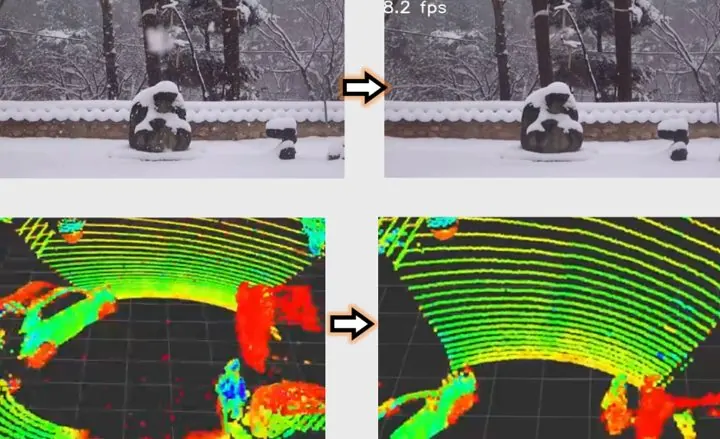
  • Desnowing Algorithms Using Camera and LiDAR Fusion

    Desnowing Algorithms Using Camera and LiDAR Fusion

    2022-2023, KAIST, KIMM

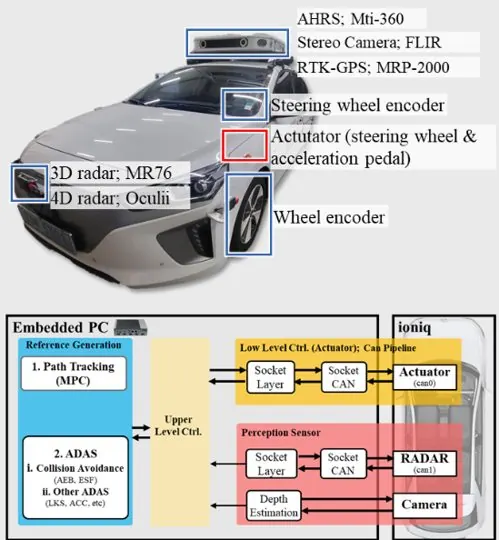
  • H/W Configurations for Autonomous Driving and ADAS

    H/W Configurations for Autonomous Driving and ADAS

    2020-2024, KAIST, FEV

Lab news

🏆 Featured

Winner, International Robotics Competition at the IEEE IROS 2025 Workshop (Wheel-Legged Robot) - IEEE IROS 2025 워크숍 국제 로보틱스 대회 우승 (휠-족형 로봇)

TagNews
AchievementSelected for the NRF Core Research Program (Basic Research B), Ministry of Science and ICT - 과학기술정보통신부 개인기초연구사업 우수연구 핵심연구(기본B) 선정
Achievement[KIEE] Award for outstanding paper (Doyoon Lee) - [대한전기학회] 우수논문상 수상 (이도윤)
Visit[Chung-Ang Univ.] Prof. Hyung Tae Choi's seminar: Nonlinear L1 control
Visit[Univ. of Michigan] Prof. Jaerock Kwon's seminar: DeepDual2Drive
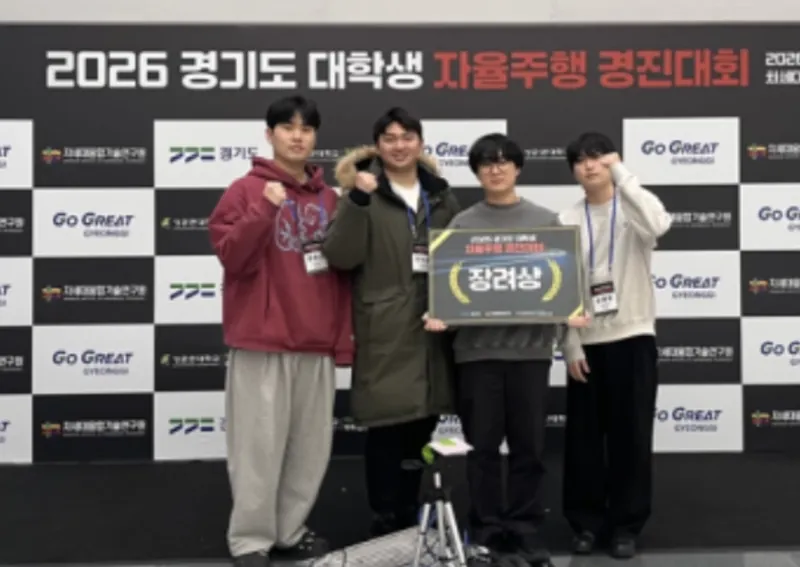
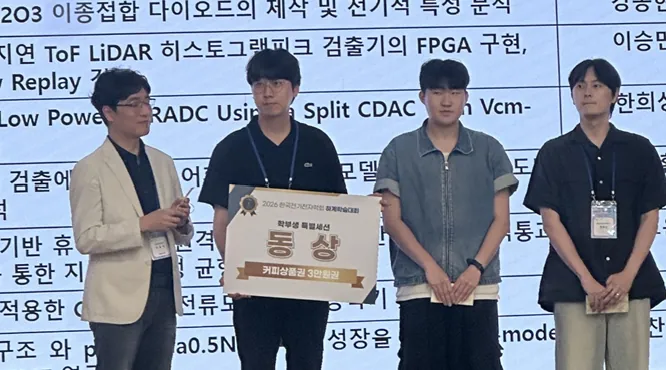
AchievementCELOS Lab students received the Encouragement Award at the 2026 Gyeonggi University Autonomous Driving Competition - 2026 경기도 대학생 자율주행 경진대회 장려상 수상
Visit[NVIDIA] Dr. Byung-Kwan Lee delivers a seminar at CELOS
Visit[KAIST] Dr. Byungkwan Jang delivers a seminar at CELOS
Visit[KIMM] Dr. Minyoung Lee delivers a seminar at CELOS
Visit[Apple] Mr. Eunkyo Seo delivers a seminar at CELOS
New[IIT] Pranav Vishal Deshmukh has joined CELOS
AchievementCELOS Lab wins the wheel-legged robot workshop competition at IROS 2025 - IROS 2025 휠-족형 로봇 워크숍 대회 우승
AchievementDoyoon Lee has been selected as a scholarship recipient (Hanyang Electronics, Information and Communication Alumni Scholarship) - 이도윤, 한양전자정보통신동문장학 장학생 선정
Visit[Imperial College London] Dr. Younggeol Cho delivers a seminar at CELOS
BirthCELOS Lab officially launched at Hanyang University - 한양대학교 CELOS 연구실 개소

Members

Professor (Principal Investigator)

Current members

  • Siheon Jo

    Siheon Jo

    Ph.D. Student

    Multi-object tracking, LiDAR, Camera

  • Ui Jin Han

    Ui Jin Han

    Undergraduate Researcher

    MPC, F1TENTH, ROS

  • Hyeonseong Lee

    Hyeonseong Lee

    Undergraduate Researcher

    MPC, F1TENTH, ROS

  • Donggyun Woo

    Donggyun Woo

    Undergraduate Researcher

    MPC, CARLA

  • YL

    Yeonseok Lee

    Undergraduate Researcher

  • Pranav Vishal Deshmukh

    Pranav Vishal Deshmukh

    Undergraduate Researcher

    Humanoid, Isaac Sim/Lab, ROS

Achievements

International
Publications
(Q1/Q2 Journal)
19(10)
Domestic
Publications
13
Patent &
Tech. Transfer
3
Awards
4

Publications

International

19+5 papers under review
  1. 2026

    4-D Radar-Camera Vector Map SLAM With Dynamic Object Removal Mask and Two-Stage Loop Detection. Choi, M., Kang, J., & Han, S. IEEE Transactions on Instrumentation & Measurement (T-IM)Q1, JCR Rank 5.6%

  2. 2026

    AcceptedRA-AEB: Risk-Aware Autonomous Emergency Braking for Collision Avoidance via a Risk Assessment Map. Choi, M., & Han, S. International Journal of Control, Automation and Systems (IJCAS)Q2, JCR Rank 38.8%

  3. 2026

    AcceptedEvolution Fine-Tuning: Learning to Discover Across 371 Optimization Tasks. Lee, Y.-J., Kim, S., Kang, M., Chuen, A. C. L., Chen, Z., Han, S., Jung, T., & Kang, D. Advances in Neural Information Processing Systems (NeurIPS 2026)

  4. 2026

    Mechanism of Post-Charge Self-Balancing in Parallel Battery Systems. Jang, B., Seo, H., Han, S., Kim, W., & Kim, K.-S. IFAC World Congress

  5. 2026

    Deep Reinforcement Learning-Based Adaptive Model Predictive Control for Autonomous Vehicle Path Tracking. Han, S., Kang, J., Deshmukh, P. V., Lee, D., & Bangunharcana, A. 15th Asian Control Conference (ASCC 2026), pp. 2321-2326

Show all (19)▾
  1. 2026

    Bridging Reactive Simulation and Log-Playback for Safer Autonomous Driving with GRPO. Bangunharcana, A., Lee, S., & Han, S. 15th Asian Control Conference (ASCC 2026), pp. 2333-2338

  2. 2026

    Fast Superquadric Potential Function for Collision Avoidance of Autonomous Vehicle. Han, S., Yang, S., & Choi, M. IEEE Access, vol. 14, pp. 6635-6646Q2, JCR Rank 33.5%

  3. 2025

    Adaptive Gait Pattern Switching under External Disturbances Using Multi-Modal MPC. Kang, J., Ham, B. I., Han, S., Kim, H., & Kim, K.-S. 34th IEEE International Conference on Robot and Human Interactive Communication (RO-MAN 2025), pp. 134-140

  4. 2025

    Adaptive ROI for Collision Warning Mitigation Based on Road Geometry and Kinematics. Han, S., Choi, M., Jang, B., Choi, K. H., & Kim, K.-S. IEEE Sensors JournalQ1, JCR Rank 19.6%

  5. 2024

    Adaptive Safety Distance for Collision Avoidance Based on a Full Braking Activation Parameter. Han, S., Choi, K. H., & Kim, K.-S. IEEE Transactions on Intelligent Transportation Systems (T-ITS)Q1, JCR Rank 2.4%

  6. 2024

    Position Uncertainty-Integrated Potential Function for Collision Avoidance Systems Based on Model Predictive Control. Han, S., Kwon, J., & Kim, K.-S. IEEE Transactions on Intelligent Vehicles (T-IV)Q1, JCR Rank 1.8%

  7. 2024

    The Leader-Follower Formation Control of Nonholonomic Vehicle With Follower-Stabilizing Strategy. Han, S., Yang, S., Lee, Y., Lee, M., Park, J. I., & Kim, K.-S. 40th Anniversary of the IEEE Conference on Robotics and Automation (IROS w/ RA-L)

  8. 2023

    The Leader-Follower Formation Control of Nonholonomic Vehicle With Follower-Stabilizing Strategy. Han, S., Yang, S., Lee, Y., Lee, M., Park, J. I., & Kim, K.-S. IEEE Robotics and Automation Letters (RA-L), vol. 9, no. 1, pp. 707-714Q1, JCR Rank 19.8%

  9. 2023

    Dynamic Control and Simulation of Leader-Follower Vehicle Formation Considering Vehicle Stability. Han, S., Choi, M., Cho, M., Park, J. I., & Kim, K.-S. International Journal of Control, Automation and Systems (IJCAS), vol. 21, no. 9, pp. 2995-3005Q2, JCR Rank 38.8%

  10. 2023

    MSC-RAD4R: ROS-Based Automotive Dataset With 4D Radar. Choi, M., Yang, S., Han, S., Lee, Y., Lee, M., Choi, K. H., & Kim, K.-S. IEEE Robotics and Automation Letters (RA-L), vol. 8, no. 11, pp. 7194-7201Q1, JCR Rank 19.8%

  11. 2023

    4D Radar-Camera Sensor Fusion for Robust Vehicle Pose Estimation in Foggy Environments. Yang, S., Choi, M., Han, S., Choi, K. H., & Kim, K.-S. IEEE Access, vol. 12, pp. 16178-16188Q2, JCR Rank 35.9%

  12. 2022

    Disturbance Observer-Based Robust Speed Control of Autonomous In-Wheel Driven Electric Vehicle. Jang, B., Han, S., Kim, Y., & Kim, K.-S. 13th Asian Control Conference (ASCC 2022), pp. 744-749

  13. 2022

    Development of ROS-Based Small Unmanned Platform for Acquiring Autonomous Driving Dataset in Various Places and Weather Conditions. Park, J. I., Choi, M., Han, S., Lee, Y., Cho, J., Choi, H., & Kim, K.-S. IEEE 46th Annual Computers, Software, and Applications Conference (COMPSAC 2022), pp. 24-31

  14. 2020

    Integrated Path Planning and Tracking Control of Autonomous Vehicle for Collision Avoidance Based on Model Predictive Control and Potential Field. Ko, C., Han, S., Choi, M., & Kim, K.-S. 20th International Conference on Control, Automation and Systems (ICCAS 2020), pp. 956-961
Domestic

13
  1. 2026

    VR 핸드 트래킹 기반 휴머노이드 원격조종의 지연 구간 분석과 저역통과필터 계수 조절을 통한 지연-안정성 균형. Lee, D., Ko, H., Yeon, J., & Han, S. Institute of Korean Electrical and Electronics Engineers (IKEEE), Summer Conference🏅 Excellent Paper Award, Bronze

  2. 2026

    Design of a Steering System Controller for Autonomous Vehicle. Jang, B., Han, S., & Kim, K.-S. Institute of Control, Robotics and Systems (ICROS)

  3. 2026

    Risk-Aware Autonomous Braking via CVaR-Based Risk Map. Cho, M., & Han, S. Institute of Control, Robotics and Systems (ICROS)

  4. 2026

    도로 노면 의미론적 분할 기법의 소수 클래스 불균형 해소를 위한 원근 변환 기반 데이터 증강 기법. Sung, M., Yoo, K., Kim, J., Han, S., Yang, S., & Choi, M. ICROS Undergraduate Paper Competition

  5. 2026

    메카넘휠 기반 이동로봇의 리더-팔로워 군집주행 제어 구현 및 검증. Lee, H., Han, U., & Han, S. ICROS Undergraduate Paper Competition

Show all (13)▾
  1. 2026

    OSMnx 및 유전 알고리즘 기반 다중 목적지 실시간 경로 최적화 시스템 구현 및 성능 분석. Lee, D., & Han, S. ICROS Undergraduate Paper Competition

  2. 2026

    nuPlan 실데이터 기반 도시별 주행 성향을 반영한 자율주행 보상 함수. Woo, D., Kim, M., Ahn, C., & Han, S. ICROS Undergraduate Paper Competition

  3. 2026

    Model Predictive Path Integral-Based Control Implementation for Off-road Autonomous Driving. Lee, H., Han, U., & Han, S. Korean Society of Automotive Engineers (KSAE), Spring Conference, Undergraduate Paper Competition

  4. 2022

    Verification of ROS-based GPS/IMU Integrated Localization Algorithm Using Inter-vehicle Distance Estimation Accuracy. Han, S., Yang, S., Lee, Y., Park, J. I., & Kim, K.-S. Korean Society for Precision Engineering, pp. 412-416

  5. 2020

    Path Tracking Algorithm Design for Unmanned Air Force Vehicle for Runway Snow Removal Operation. Han, S., Song, H.-J., Lee, M.-Y., Cha, M.-H., & Kim, K.-S. Korean Journal of Military Art and Science

  6. 2020

    Development of Collision Avoidance Controller for Autonomous Vehicle based on Potential Field and Model Predictive Control. Han, S., Ko, C., & Kim, K.-S. Korean Society for Precision Engineering, p. 262

  7. 2020

    Dynamic Modeling of Unmanned Military Vehicle for Runway Snow Removal Operations and Simulation Environment Construction for Driving Performance Evaluation. Han, S., et al. Korean Society of Mechanical Engineers, pp. 157-159

  8. 2020

    Simulation Verification of Unmanned Military Trailers for Runway Snow Removal Operations. Han, S., et al. Korean Society of Mechanical Engineers, pp. 160-162

Patents and technology transfer

3
  1. 2026

    Manipulator Fallback Algorithms Using Robust Tube-Based Control. Han, S. Technology Transfer (Hanyang Univ.)

  2. 2026

    Tube Neural Networks for Robust Robot Control and Vibration Suppression. Han, S. Technology Transfer (Hanyang Univ.)

  3. 2025

    Autonomous Emergency Braking Method for Providing Optimal Safety Distance and System. Han, S., Choi, K. H., & Kim, K.-S. Patent (KAIST), 10-2025-0042188

Awards

Invited seminars and workshops

  1. 2026

    Korean Society of Automotive Engineers (KSAE) - 한국자동차공학회

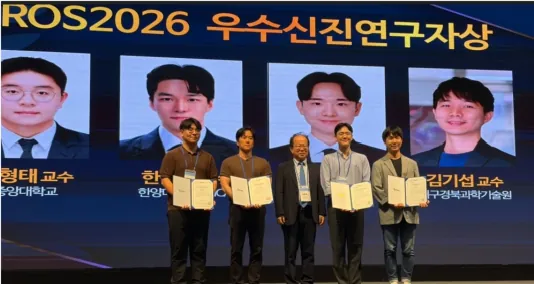
    2026 Spring Conference, Outstanding Early-Career Researcher session - 2026 춘계, 신진과학자세션 발표

  2. 2026

    Institute of Control, Robotics and Systems (ICROS) - 제어로봇시스템학회

    2026, Outstanding Early-Career Researcher session - 2026 우수신진연구자세션 발표

  3. 2026

    ASCC 2026

    Special Session

  4. 2026

    Kwangwoon University - 광운대학교

    Wheel-torque distribution strategy for formation control of mobile robot - 모바일로봇 군집제어를 위한 휠-토크 분배 전략

  5. 2026

    ICROS Workshop - 제어로봇시스템학회 워크숍

    Integration of reinforcement learning and stochastic MPC and its application to wheel-legged robot control - 강화학습 및 Stochastic MPC 융합방법론과 이를 이용한 wheel-legged robot 제어

  6. 2026

    ROSCon

    High-speed autonomous navigation of a wheel-legged robot using reinforcement learning - 강화학습을 이용한 wheel-legged robot (휠-다리 로봇)의 고속 자율주행 구현

  7. 2025

    Korea Institute of Information Security and Cryptology (KIISC) - 한국정보보호학회

    Communication-delay compensation for connected autonomous driving and RL-based adversarial manipulation of sensor data - 커넥티드 자율주행 통신 지연 보상 기법 및 센서 데이터의 강화학습 기반 악의적 조작

  8. 2024

    Korea University - 고려대학교

    LiDAR-radar fusion for robust multi-object tracking - 라이다-레이다 퓨전을 이용한 강인한 다중객체 추적

  9. 2024

    Chungnam National University - 충남대학교

    Fundamentals of nonlinear MPC and its application on autonomous driving - 비선형 MPC 기초 및 이를 응용한 자율주행

  10. 2024

    Chungnam National University - 충남대학교

    Fundamentals of linear MPC - 선형 MPC 기초

  11. 2024

    Kyonggi University - 경기대학교

    Fundamentals of linear MPC - 선형 MPC 기초

Ongoing projects

PeriodProject nameBudget [KRW]
2026.09 ~2031.08

Core Research Program (Basic Research B), Excellent Research Track - 개인기초연구사업 우수연구 핵심연구(기본연구B)Ministry of Science and ICT (NRF)

315,000,000
2026.03 ~2026.12

(Advanced GPU) Large-scale reinforcement learning-based control of wheel-legged robots for unstructured terrain - (첨단 GPU) 비정형 지형 극복을 위한 휠-족형 로봇의 대규모 강화학습 기반 제어National IT Industry Promotion Agency (NIPA)

97,961,600(in kind)
2026.01 ~2026.12

2026 Regional Industry-Linked University-Company OpenLab Program - 2026 지역 중점산업 기반 대학기업 연계형 OpenLab 육성지원 사업Gyeonggi Province

75,000,000
2025.09 ~2027.02

Stability-guaranteed embedded AI controllers and RL-based control and pose estimation for rough-terrain autonomous systems - 안정성이 보장된 임베디드 AI 제어기 설계 및 이를 활용한 강화학습 기반 험지 자율시스템 제어 및 자세추정 알고리즘 설계Hanyang University

40,000,000
-

Advanced Industry Talent Bootcamp (Semiconductor) - 첨단산업 인재양성 부트캠프 사업 (반도체)Korea Institute for Advancement of Technology (KIAT)

-
2020.09 ~2027.08

BK21 FOUR, Education and Research Group for Intelligent Next-Generation IoT - BK21 (두뇌한국21), 학연산 기반 지능형 차세대 사물통신 실용인재 양성 교육연구단Ministry of Education (NRF)

-
2021.05 ~2027.02

Convergence and Open Sharing System (COSS), Intelligent Robots - 첨단분야 혁신융합대학사업 (지능형 로봇)Ministry of Education (GBSA)

-

Recruiting

Join the CELOS Lab

■ 진로면담을 희망하거나, 석박사과정 진학/학부인턴 희망자는 설문지를 클릭하여 작성해주세요. (5분)

■ If you would like to schedule a meeting with the advisor, please click the survey link and complete it. (5 mins)