Skip to content
← Back to CELOS Lab
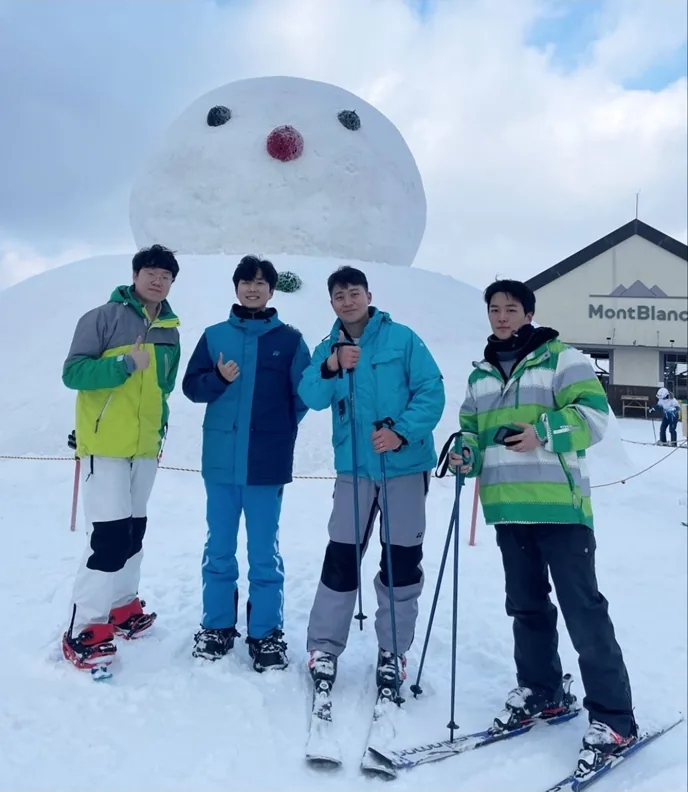
Seungho Han skiing with colleagues

Principal Investigator

Prof. Seungho Han 한승호

Assistant Professor, Electrical Engineering and Mechanical Engineering (joint appointment), Hanyang University

Office
Room 402, Engineering Building 3 (제3공학관 402호)
Research Topics
Optimal control, Reinforcement learning-based control, Autonomous vehicle/robot

Research Experiences & Educational Background

■ Assistant Professor

09/2025 - Current
  • School of Electrical Engineering, Department of Mechanical Engineering (joint appointment), Hanyang University

■ Staff Engineer

09/2024 - 08/2025

  • - 책임연구원-과장, 삼성전자 생산(설비)기술연구소 AI로봇기술그룹
  • - AI Robotics Research, A-FAB Team, Samsung Electronics, Hwaseong
Samsung Electronics

■ Ph.D.

08/2021 - 08/2024

  • - Mechanical Engineering (Advisor: Prof. Kyung-Soo Kim)
  • Korea Advanced Institute of Science and Technology (KAIST), Daejeon

■ Research Associate

02/2021 - 08/2021

  • - 위촉연구원, 카이스트 MSC연구실
  • Mechatronics, Systems and Control (MSC) Lab, KAIST, Daejeon

■ M.S.

02/2019 - 02/2021

  • - Mechanical Engineering (Advisor: Prof. Kyung-Soo Kim)
  • Korea Advanced Institute of Science and Technology (KAIST), Daejeon

■ B.S.

03/2013 - 02/2019

  • - Mechanical Engineering
  • Hanyang University, Seoul (Summa Cum Laude; 최우등졸업)
Academic Experiences

■ Invited Reviewer

  • - International Journal of Control, Automation, and Systems (IJCAS)
  • - International Journal of Automotive Technology (IJAT)
  • - IEEE Transactions on Instrumentation and Measurement (IEEE TIM)
  • - IEEE Transactions on Vehicular Technology (IEEE TVT)
  • - IEEE Transactions on Automation Science and Engineering (IEEE TASE)
  • - IEEE Transactions on Mechatronics (IEEE TMECH)
  • - IEEE Transactions on Intelligent Transportation Systems (IEEE TITS)
  • - IEEE Transactions on Control Systems Technology (IEEE TCST)
  • - IEEE Robotics and Automation Letters (IEEE RA-L)
  • - IEEE International Conference on Intelligent Robots and Systems (IEEE IROS)
  • - IEEE American Control Conference (IEEE ACC)
  • - Nonlinear Dynamics
  • - International Journal of Intelligent Robotics and Applications
  • - International Journal of Machine Learning and Cybernetics

■ Research Association (부문/연구회)

  • - 제어로봇시스템학회 (ICROS, Institute of Control, Robotics and Systems), 자동차제어 연구회 (Technical Committee on Automotive Control), 2025 - Current
  • - 한국자동차공학회 (KSAE, Korean Society of Automotive Engineers), 자율주행전장 부문, 2026 - Current

■ Academic Service

  • - Technical Committee, Asian Control Conference (ASCC), 2026
  • - Organizing Committee, 제어로봇시스템학회 학술대회 (ICROS, Institute of Control, Robotics and Systems), 2026
  • - Co-Organizer, Special Session "Recent Advances in Planning and Control for Autonomous Driving", Asian Control Conference (ASCC), 2026

■ Invited Seminar/Workshop/Talk

  1. 1.Korean Society of Automotive Engineers (KSAE) - 한국자동차공학회 (2026), 2026 Spring Conference, Outstanding Early-Career Researcher session - 2026 춘계, 신진과학자세션 발표
  2. 2.Institute of Control, Robotics and Systems (ICROS) - 제어로봇시스템학회 (2026), 2026, Outstanding Early-Career Researcher session - 2026 우수신진연구자세션 발표
  3. 3.ASCC 2026 (2026), Special Session
  4. 4.Kwangwoon University - 광운대학교 (2026), Wheel-torque distribution strategy for formation control of mobile robot - 모바일로봇 군집제어를 위한 휠-토크 분배 전략
  5. 5.ICROS Workshop - 제어로봇시스템학회 워크숍 (2026), Integration of reinforcement learning and stochastic MPC and its application to wheel-legged robot control - 강화학습 및 Stochastic MPC 융합방법론과 이를 이용한 wheel-legged robot 제어
  6. 6.ROSCon (2026), High-speed autonomous navigation of a wheel-legged robot using reinforcement learning - 강화학습을 이용한 wheel-legged robot (휠-다리 로봇)의 고속 자율주행 구현
  7. 7.Korea Institute of Information Security and Cryptology (KIISC) - 한국정보보호학회 (2025), Communication-delay compensation for connected autonomous driving and RL-based adversarial manipulation of sensor data - 커넥티드 자율주행 통신 지연 보상 기법 및 센서 데이터의 강화학습 기반 악의적 조작
  8. 8.Korea University - 고려대학교 (2024), LiDAR-radar fusion for robust multi-object tracking - 라이다-레이다 퓨전을 이용한 강인한 다중객체 추적
  9. 9.Chungnam National University - 충남대학교 (2024), Fundamentals of nonlinear MPC and its application on autonomous driving - 비선형 MPC 기초 및 이를 응용한 자율주행
  10. 10.Chungnam National University - 충남대학교 (2024), Fundamentals of linear MPC - 선형 MPC 기초
  11. 11.Kyonggi University - 경기대학교 (2024), Fundamentals of linear MPC - 선형 MPC 기초

Life Experiences

■ Military Service

04/2014 - 12/2015

  • - Served as a Sergeant (completed)

■ RACE

02/2016 - 07/2017

  • - Student Society, 레이스 동아리, Hanyang University, Seoul
RACE student society logo

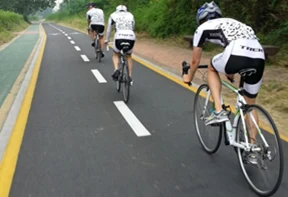
■ Cross Country Cycling

2013, 2018

  • - 싸이클 국토종주, Incheon ~ Busan, 630 km / 4 days, Team Leader
Cross country cycling

Lectures

■ Graduate Courses

  • - (Spring) Optimal Control and Reinforcement Learning-Based Control for Autonomous Robots and Driving
Spider 30 (Diden Robotics)

■ Undergraduate Courses

  • - (Spring) Robotics (w/ Canon Korea)
  • - (Spring) Control Systems Modeling
  • - (Fall) Robot Vision and AI
  • - (Fall) Linear Algebra